NVIDIA Isaac ROS 5.0 Advances Agentic, Open Source Robotics Development
NVIDIA released Isaac ROS 5.0 at ROSCon 2025, adding agentic workflows and ROS Lyrical support to accelerate robotics development with GPU-accelerated tools and open source libraries.
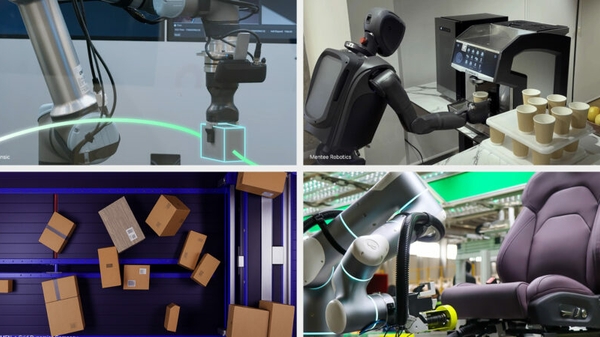
NVIDIA Isaac ROS 5.0, unveiled at ROSCon in Toronto, expands the open-source robotics framework with GPU-accelerated packages designed to help developers and AI agents collaborate on building, customizing, and deploying robotics applications. The update introduces agentic workflows that automate repetitive tasks, enabling faster iteration from concept to deployment while maintaining compatibility with the ROS ecosystem used by nearly 1.3 million developers. By leveraging NVIDIA’s accelerated computing and physical AI models, the release aims to streamline the creation of high-performance robotics systems using familiar open-source tools.
The new version adds support for ROS Lyrical and Ubuntu 24.04, providing developers with a pathway to adopt the latest ROS platform while continuing to accelerate computationally intensive workloads. NVIDIA contributed a standard data-handling interface to ROS Lyrical, enabling efficient cross-hardware software operation, including GPUs, and offering a consistent method to accelerate robotics applications with CUDA as a reference implementation.
New reusable workflows, termed NVIDIA Isaac skills, simplify robotics development tasks for both developers and AI agents. These include a FoundationStereo fine-tuning skill for adapting stereo perception models to specific camera setups and an agent-ready FoundationPose inference library that accelerates object pose estimation and tracking up to 5.5 times compared to prior methods.
The release also introduces a standalone pick and place skill, expanding flexibility beyond existing Isaac ROS capabilities. The broader robotics ecosystem is adopting these agentic approaches, with projects like AgenticROS integrating Isaac ROS with NVIDIA models and tools, while hardware partners such as RealSense and Seeed Studio optimize their platforms for Isaac ROS and NVIDIA Jetson Thor.